An efficient acyclic contact planner for multiped robots
T-RO 2018 and ISRR 2015
Steve Tonneau, Andrea Del Prete, Julien Pettré, Franck Multon, Chonhyon Park, Dinesh Manocha and Nicolas Mansard
T-RO and ISRR 2015
Abstract
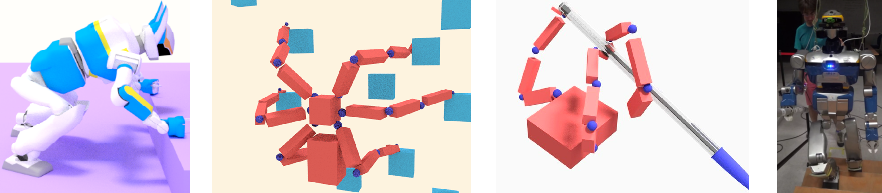
We present a contact planner for complex legged locomotion tasks: standing up, climbing stairs using a handrail, crossing rubble and getting out of a car. The need for such a planner was shown at the Darpa Robotics Challenge, where such behaviors could not be demonstrated (except for egress).
Current planners suffer from their prohibitive algorithmic complexity, because they deploy a tree of robot configurations projected in contact with the environment.
We tackle this issue by introducing a reduction property: the reachability condition. This condition defines a geometric approximation of the contact manifold, which is of low dimension, presents a Cartesian topology, and can be efficiently sampled and explored.
The hard contact planning problem can then be decomposed into two sub-problems: first, we plan a path for the root without considering the whole-body configuration, using a sampling-based algorithm; then, we generate a discrete sequence of whole-body configurations in static equilibrium along this path, using a deterministic contact-selection algorithm.
The reduction breaks the algorithm complexity encountered in previous works, resulting in the first interactive implementation of a contact planner (open source). While no contact planner has yet been proposed with theoretical completeness, we empirically show the interest of our framework: in a few seconds, with high success rates, we generate complex contact plans for various scenarios and two robots, HRP-2 and HyQ. These plans are validated either in dynamic simulations, or on the real HRP-2 robot.
Materials
T-RO journal. I recommend reading this paper, which is the most exhaustive presentation of the approach: “An efficient acyclic contact planner for multiped robots” Paper · Video
ISRR 2015 conference paper: “A reachability-based planner for sequences of acyclic contacts in cluttered environments” Paper · ISRR 2015 video
Extension of the planner to dynamic cases (by my PhD student Pierre Fernbach, with Michel Taïx): “A kinodynamic steering-method for legged multi-contact locomotion” Paper · IROS 2017 video
Integration of the planner within a centroidal trajectory generator (by Justin Carpentier et al.): “A versatile and efficient pattern generator for generalized legged locomotion” Paper
Installation and technical details of the software can be found here.
BibTeX entries are available from the publications page.
Videos
Technical report video
Execution of the plan on HRP-2 (30s)
ISRR video